NASA HECC Centrifugal Impeller: The Dilemmas
The dilemmas of the NASA HECC centrifugal impeller case, each told as its situation, the risk had it been missed, how it was noticed, the resolution and the evidence that the resolution held. The case, the set-up, the results and the honest limits are on the case page.
The dilemmas
Unless a dilemma says otherwise, its numbers were measured on HiNC 3.2.39 on a 32-core server at 1 mm.
The coordinates have no unit
- Situation. The files give an exit radius of 8.49376, with no unit.
- Risk. A part 25.4 times too small or too large.
- How it was noticed. At once: no file names a unit.
- Resolution. Compared with the report's Table 2, the coordinates are inches; used at 1:1.
- Evidence it held. Three diameters match the table to its last digit: 2 × 1.5949 = 3.190, 2 × 2.6574 = 5.315 and 2 × 8.49376 = 16.988 in.
A 4.93 GB download for 0.2 MB of data
- Situation. The supplement is one 4.93 GB zip; the case needs 25 files, about 0.2 MB.
- Risk. Downloading 4.93 GB for them.
- How it was noticed. The file size on the record page.
- Resolution. The server did not advertise range support but answered a ranged request with a partial response, so the agent read the zip's table of contents and the 25 entries by byte range.
- Evidence it held. About 5 MB came down; every entry passed its CRC check, and the source notes list each file's SHA-256.
What the licence allows
- Situation. The record says Public Use Permitted, but the data belong to a contractor report, not a U.S. Government work, and the record defines no scope and names no licence or rights holder.
- Risk. Overstating the right to use and redistribute the files.
- How it was noticed. The agent's first notes called the data not copyrighted; the record's API
fields (
belongsToUsGov: false,licenseType: NO) say no such thing. A later review had the notes state what the determination leaves undefined. - Resolution. The record is quoted field by field, the authors credited in a fixed line, and the backup copy rests on this reading and is removed at the rights holder's request.
- Evidence it held. The case takes only the folder stated to be “not subject to the EAR or the ITAR”, and none of the supplement's export-marked files.
Which five-axis machine?
- Situation. HiNC's library has only a three-axis generic chain; its five-axis models are third-party machines not licensed for this use, and its one holder file carries a third party's name.
- Risk. A vendor's machine on a public page, or no machine at all.
- How it was noticed. Going through the library before building.
- Resolution. A script generates a table-C, head-B machine from boxes, cylinders and cones, the same file byte for byte on every run; the holder is a Z–R profile in the project (Attaching and Building the Machine Chain).
- Evidence it held. HiNC bound all five axes, the program-zero call put the spindle nose 700 mm above the table as built, and the whole job raised no stroke-limit message.
How short can the stick-out be?
- Situation. The owner asks for the shortest stick-out that is enough; a shrink-fit grips only the cylindrical shank, which the taper reaches at 88.9 mm. The deepest passage is 67.5 mm, about 69 mm along the 12° lean and more where the axis tilts further.
- Risk. A chuck clamping the taper or rubbing a blade, or a cantilever no shop would run.
- How it was noticed. Setting the tool against the deepest passage before computing the path.
- Resolution. 92 mm, leaving 3 mm of plain shank. The generator keeps the unfluted taper, shank and holder 1 mm from every blade and the hub at heights 2–3 mm apart up to the chuck, 5–20 mm along it; it does not compare the depth along a steeply tilted axis with the 70 mm flute.
- Evidence it held. No tool position was dropped; HiNC reads back a tool length of 194 mm.
How far is the tool from a blade?
- Situation. The agent's generator checks clearance against 1.1 million blade samples up to 1.4 mm apart.
- Risk. The nearest-sample distance overstates clearance by about 0.1 mm, enough to cut a blade root.
- How it was noticed. An adversarial review. The first fix, each sample's tangent plane, understated it past a blade edge: 35,271 positions dropped, blade finishing cut from 30.1 to 11.5 m per passage.
- Resolution. A tangent plane is trusted only within its sample's patch (±0.75 mm).
- Evidence it held. No position dropped, 30.1 m again, and the whole job's comparison shows the passages and blade faces within ±0.1 mm.
A design model that was not closed
- Situation. The Python Boolean library the agent used (manifold3d, which unites and trims solids) works in 32-bit floats; reloaded from STL, the design model had 86 zero-area triangles and was not watertight.
- Risk. An open model under the geometry comparison.
- How it was noticed. An adversarial review reloaded the file.
- Resolution. Vertices merged and degenerate faces dropped before export; both meshes reloaded.
- Evidence it held. Closed on reload: design model 461,378 triangles and 5,653.8 cm³, blank 68,400 and 10,593.7 cm³.
Retracts that grazed the part, entries that fed too fast
- Situation. HiNC reported
Play-RapidCut--Detected(a rapid touching the part) at each retract's start, the tool still touching about 0.00001 mm³. And entries fed their last 3 mm, 2.5 mm in material, at the 1,800 mm/min cutting feed. - Risk. Rapids starting in contact, a real one lost among them; an end mill driven axially at a cutting feed.
- How it was noticed. HiNC's messages; an adversarial review.
- Resolution. Retracts feed their first 5 mm along the axis, then rise to 8 mm outside the blank, or the full 100 mm when the hop is not clear outside the blank, is longer than 80 mm or turns the axis over 10° (while such a hop turns the tool axis, the shank and holder swing through the passage even though the tip moves straight). Entries rapid to 8 mm outside the blank and feed in at 900 mm/min.
- Evidence it held. The whole job raised no
Play-RapidCut--Detectedand no collision.
HiNC's physics read the tool far above its stress limit
- Situation. With physics on for the last passage's hub finishing, the tool's stress ratio (the
largest principal stress the cutting forces cause in the tool body, over the tool material's stress
limit: in this case's copy of
WC-Co10-600nm, which has no yield point, its tensile strength of 1,680 MPa) peaked at 350 % at the inlet, three and a half times the limit, where 100 % or more is bad machining (Evaluating Process Machinability). - Risk. A tool loaded far past its stress limit in the part. A stress ratio of 100 % does not mean the tool breaks, but a cut should still stay under 100 %: the chance of a break rises with the stress, and the breakage probability gives it for each step.
- How it was noticed. HiNC's stress-ratio chart, then its per-step values.
- Resolution, in three steps:
- The ball cut with its tip, where the cutting speed is zero; a 12° downstream lean made it cut with its side.
- Cut across the channel, the hub pass swung the axis 15–20° within 0.4 mm near the walls, so the flank 30–60 mm up swept the material many times faster than the tip. The hub was recut along flow lines with an axis-smoothing pass: jumps over 6° fell from 303 to 23.
- The 99th percentile fell to 34.4 %, but the peak rose to 420 % where the axis still jumped. Finishing now turns the axis at most 4° between cut points; larger turns happen in the air.
- Evidence it held. At 0.5 mm, over the passage's 26,995 cutting steps: median 10.8 %, 99th percentile 34.4 %, maximum 94.4 %, force at most 483 N (measured before the local links, which left the cut points unchanged). At 1 mm a single step after an entry reads 126 %, where the coarser stock overstates the engagement.
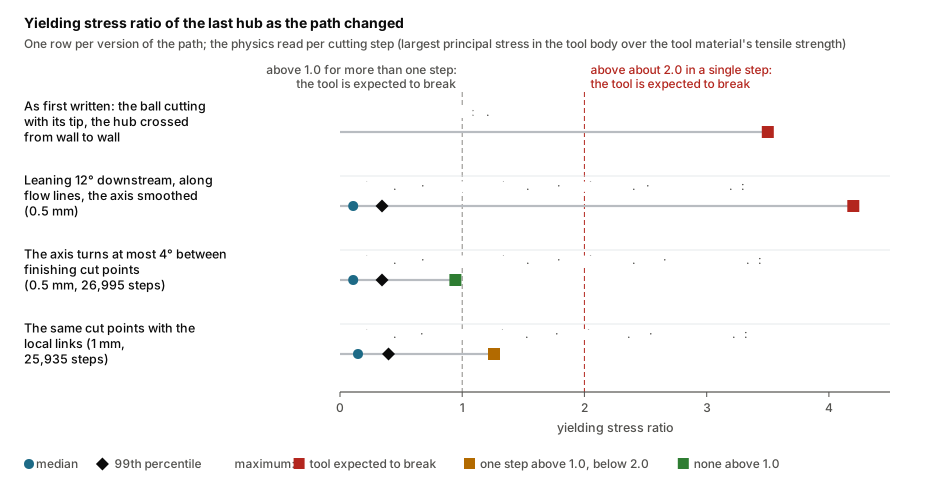
The last hub's stress ratio as the path changed: one row per version of the path, the dot the median, the diamond the 99th percentile and the square the maximum, red at or above 100 %, the stress limit, where the machining is bad, and green under it. Read per cutting step on HiNC 3.2.39.
The last hub's cutting steps as the path changed, read step by step on HiNC 3.2.39:
| Path of the last hub | Resolution | Cutting steps | Stress ratio: median / 99th percentile / maximum | Steps above 100 % | Force: 99th percentile / maximum |
|---|---|---|---|---|---|
| As first written: the ball cutting with its tip, the hub crossed from wall to wall | — | — | maximum 350 % | — | — |
| Leaning 12° downstream, along flow lines, the axis smoothed | 0.5 mm | — | 10.8 % / 34.4 % / 420 % | 5 | — |
| Turning at most 4° between finishing cut points | 0.5 mm | 26,995 | 10.8 % / 34.4 % / 94.4 % (90th percentile 26.1 %) | 0 | 175 / 483 N |
| The same cut points with the local links | 1 mm | 25,935 | 14.7 % / 39.7 % / 126 % | 1 | 201 / 647 N |
Numbers that look alarming but are not
- Situation. Read naively, the charts showed eight times the programmed feed, chips up to 0.88 mm thick against 0.067 mm per tooth (2,400 ÷ 12,000 rpm ÷ 3 flutes), and, at 0.5 mm, infinite depth in 13 % of the hub's cutting steps.
- Risk. Rewriting a sound path to chase a readout while a real overload hides in the same chart: the first path showed such readouts (0.4–0.9 mm chips, 30–60 mm depth) with its real fault.
- How it was noticed. The numbers contradicted the path's own feeds.
- Resolution. Values are read per step, where the tool touches (Watching the Run): a chart window's maximum is dominated by rapids and plunges; at 0.5 mm the chip readout jumps in steps of 0.12 mm, reading 0.39, 0.51, 0.63 or 0.75 mm in about a quarter of the hub's cutting steps; each infinite depth is a single step between neighbours of 1–3 mm. Stress ratio and force judge the cut, and told the first path's fault apart.
- Evidence it held. Stage C's 25,935 cutting steps run at 2,400 mm/min at the median, the 99th percentile and the maximum; sampled thick-chip steps are steady cuts at 130–170 N.
Where the memory went
- Situation. One passage of an early path peaked at 24.4 GB at 0.5 mm and 88.5 GB at 0.25 mm, both in the geometry comparison, against 3.3 GB while cutting at 0.5 mm (measured on HiNC 3.2.39, and the whole part not measured again; with the current comparison the trial of passage 1 peaked at 4.21 GB at 0.5 mm and 8.05 GB at 0.25 mm on HiNC 3.2.56, see Geometry Validation). A reload or a restart clears the run's results.
- Risk. A run that runs out of memory, peaks that include the previous run, and values that can no longer be read.
- How it was noticed. Memory logged every 30 s; one whole-job run lost its results to a reload and was played again.
- Resolution. The resolution follows the purpose, and the job can run stage by stage with the comparison last. HiNC is restarted before each measured run, and every value read in that session. The budget: about 4.6 GB per million steps, then about 10 GB for the comparison at 1 mm and 3 GB for the NC conversion (Memory Planning).
- Evidence it held. The stages peaked at 7.2, 9.1 and 12.1 GB against 23.5 GB for the whole job in one run: within 16 GB with a restart between stages, though no 16 GB computer was tried.
One passage of an early path, 135,162 steps, at three resolutions, on HiNC 3.2.39:
| Resolution | Wall time | Memory while cutting | Peak, in the comparison |
|---|---|---|---|
| 1 mm | 317 s | — | 11.8 GB, in a process that had run before |
| 0.5 mm | 504 s | 3.3 GB | 24.4 GB |
| 0.25 mm | 1,143 s | about 13 GB | 88.5 GB |
The whole part at 0.5 mm, the resolution of the pictures:
| Run | Steps | Wall time | Peak memory |
|---|---|---|---|
| Whole job on an early path, no comparison | 2,108,965 | 5,338 s | 15.4 GB |
| Resumed at B: B, C and the picture pose, on the path before the local links, no comparison | 1,422,277 | 3,651 s | 18.2 GB |
| Every stage read from its record, the picture pose played, then the whole-part comparison | 42 | 207 s | 40.4 GB |
A resumed run that silently starts over
- Situation. The staged mission must resume at stage B or C from the earlier stages' records.
- Risk. A resumed run that recuts the raw stock without a message.
- How it was noticed. Working out from HiNC's source when a record is read; unticking a whole stage skips its records too. The agent's first account of the rule was wrong; the second review round caught it.
- Resolution. A Read On First Or Write record is read only if its file exists and nothing has played yet in the run, so a resume unticks only the earlier stages' program rows; an STL stock needs a stage-0 record (A Mission That Resumes).
- Evidence it held. Resumed at B, then C, the runs ended with the whole job's part; the stage counts sum to 99 steps fewer than the whole job's.
The owner saw strange lifts
- Situation. Where the straight move between two finishing cuts was refused, the tool left the blank, rising up to 95 mm: 1,406 times to bridge a short gap, with a median lift of 55 mm.
- Risk. About 1 h 25 min of wasted simulated time, and a path no machinist would accept.
- How it was noticed. The owner picked one on HiNC's canvas, a 30 mm rise and fall to cross 10.7 mm; the agent counted the rest.
- Resolution. Local links, in finishing only: lift 1.5 mm off the surface (up to 12 mm if needed), cross in steps of 1 mm and 2°, come down at 900 mm/min, every pose checked. The first version lifted along the nearer surface's normal and failed at the owner's own spot, a wall-hub corner 3.00 and 3.01 mm away; lifting along the bisector passed.
- Evidence it held. 1,380 links became local; stage C's per-step physics is unchanged; simulated time fell from 49,139 s (13 h 39 min) to 44,002 s (12 h 13 min).
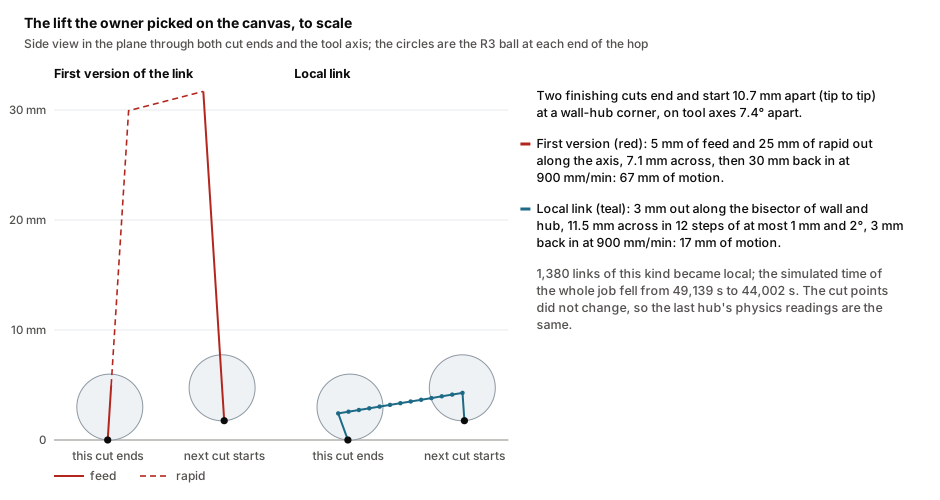
The same hop two ways, to scale in one side view through both cut ends and the tool axis (the coordinates are the case's final CL): the two finishing cuts end and start 10.7 mm apart, tip to tip, at a wall-hub corner, on tool axes 7.4° apart. The first version fed 5 mm and rapided 25 mm out along the axis, crossed 7.1 mm and fed 30 mm back in at 900 mm/min; the local link lifts 3 mm, crosses 11.5 mm in 12 steps and comes down 3 mm at 900 mm/min. The cut points did not change, so the last hub's physics readings are the same.
How the programs pass from one cut to the next after the change (the counts leave out each operation's first approach and last retract):
| Program | Straight feed move | Local link | Out to 8 mm outside the blank | Full 100 mm retract |
|---|---|---|---|---|
| Roughing, passages 1–15 | 32,685 | none: roughing never links locally | 315 | 855 |
| Walls of all 30 blades, then the hubs of passages 1–14 | 3,208 | 1,380 | 14 | 147 |
| Hub of passage 15 | 77 | 15 | 1 | 3 |
Pictures that show the part as it is
- Situation. Surfaces cut in the current run render pink, a built comparison stays on screen until the next run, and selecting a chart step does not move the machine.
- Risk. A pink part, a coloured one, or a tool parked far from the work.
- How it was noticed. The first renders.
- Resolution. The pictures come from a run that reads the stage records and plays only a short pose path re-tracing a finished wall, at 0.5 mm, on the path before the local links.
- Evidence it held. That run cut nothing in 15 s; with the comparison on it took 207 s and 40.4 GB.
Which splitter belongs to which passage
- Situation. In this data the splitter between main blade 0 and main blade 1 is splitter 1, not splitter 0: each splitter's THETA is about 12° less than that of the main blade with the same number.
- Risk. Picking the splitter by its number puts the passage's boundary on the wrong blade, and the path then runs through a blade.
- How it was noticed. From the THETA values of the sections.
- Resolution. The path script does not hard-code the splitter: passage 1 is the free run between main blade 0 and main blade 1 on the circle the ball centre follows, and the splitter inside it is whichever splitter label sits between them (here splitter 1).
- Evidence it held. Passage 1 took splitter 1; the whole job's comparison shows the passages and blade faces within ±0.1 mm, and no collision was reported.
A summary that looked like a wrongly read record
- Situation. The agent's play script printed the message summary with one text per message id, so
in the run resumed at stage B the two
ReadMeshedGeommessages both showedA-init.wct. - Risk. Believing that the resumed run read the wrong record.
- How it was noticed. Reading the run summary.
- Resolution. HiNC's source shows that each read uses the file name of its own row.
- Evidence it held. The two reads were A-init and A-done, and that run ended with the whole job's part (see the resumed-run dilemma above).
Closing the project after a restart returns 400
- Situation. After a restart HiNC has no project loaded, and
POST /api/Project/closeanswers 400No project is currently loaded. - Risk. A rebuild script that stops on this error before it has built anything.
- How it was noticed. Every measured run began with a restart and then a rebuild of the project.
- Resolution. The rebuild script tolerates this 400, deletes the old project file and builds the project anyway.
- Evidence it held. The rebuild straight after a restart ran through.
Source and licence
The impeller geometry these dilemmas work from comes from G. Medic et al., High Efficiency Centrifugal Compressor for Rotorcraft Applications, NASA/CR-2014-218114/REV1, https://ntrs.nasa.gov/citations/20180001471, and its supplement, https://ntrs.nasa.gov/citations/20180001472; if the links move, search for NASA/CR-2014-218114. The record's copyright determination is Public Use Permitted, and NASA's terms of use for its scientific and technical information apply. The 25 files are used byte for byte and everything else is the agent's; the backup and the files' SHA-256 are under Source and licence on the case page.
Impeller geometry from NASA/CR-2014-218114/REV1, “High Efficiency Centrifugal Compressor for Rotorcraft Applications”, G. Medic et al., United Technologies Research Center, for NASA Glenn Research Center; supplement https://ntrs.nasa.gov/citations/20180001472 (Appendix E.4 hot coordinates; NTRS copyright determination: Public Use Permitted). Tech Coordinate lofted the surfaces and made the blank, tool path, tool, holder and machine set-up; NASA does not endorse Tech Coordinate, HiNC or this case.
Under NASA's terms the data are provided as is, without warranty. No NASA logo is used.
See Also
- NASA HECC Centrifugal Impeller — the case these dilemmas belong to: the source data, the set-up, the results and the honest limits
- Showcase — the other cases and how a case page reads